
Computing
Perception Systems
Perception Systems
Captures and interprets environmental and motion data
• Camera
• LiDAR
• Microphone
• Inertial measurement unit (IMU)
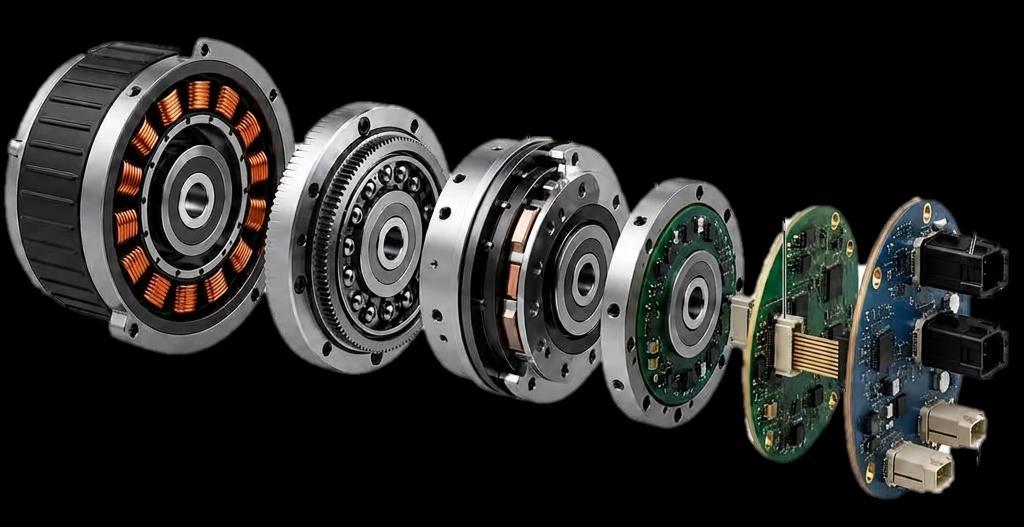
Enables the precise force, control and responsiveness for mobility
• Arms
• Legs
• Joint motors
• Encoders
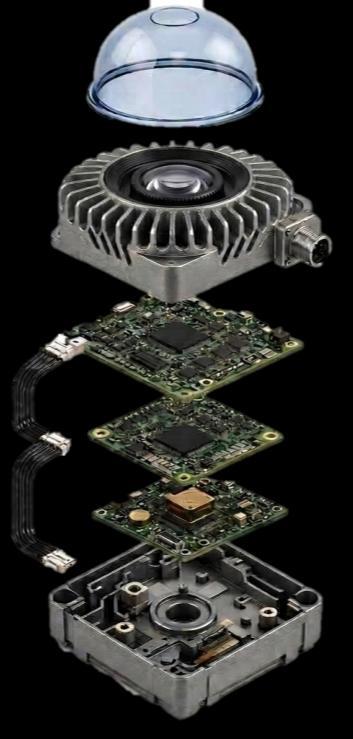
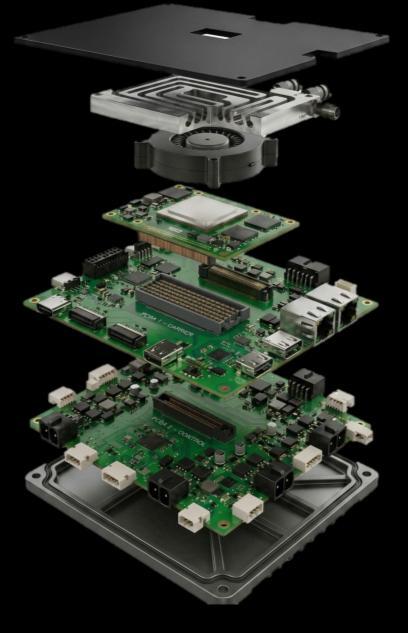
Computing
Processes sensor inputs and controls robotic movement
• Main PCB
• AI processing
• Motion control
• I/O Board
Power Distribution
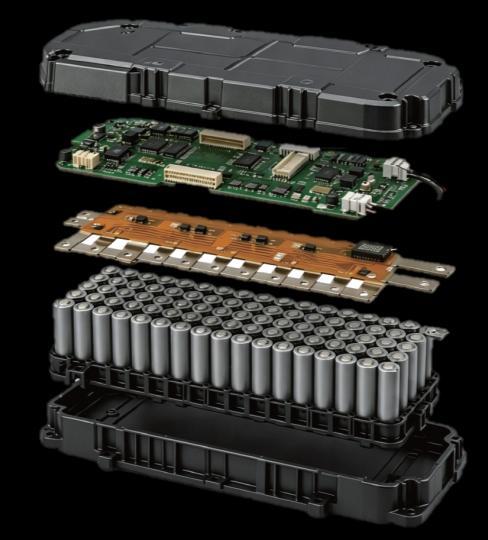
Delivers and manages system power across the robot
• Battery
• Battery management system
• Power routing
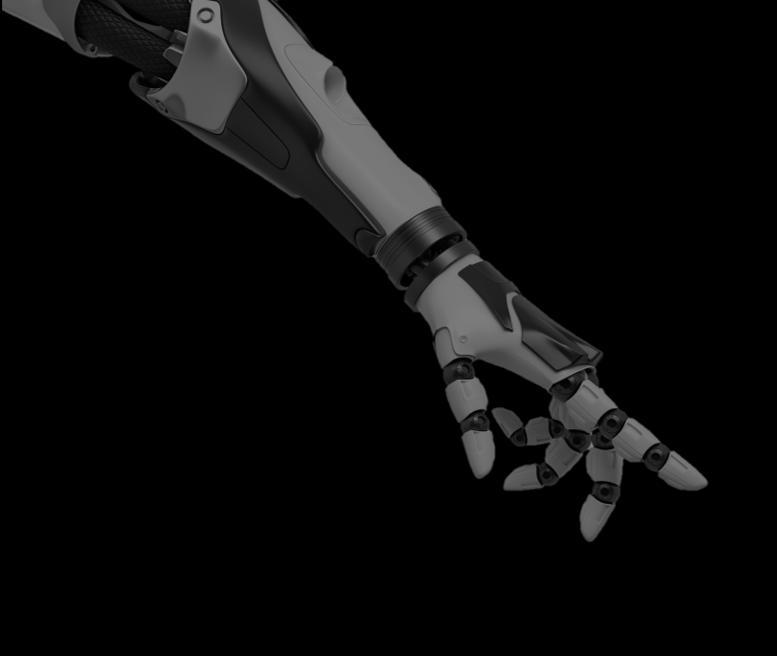
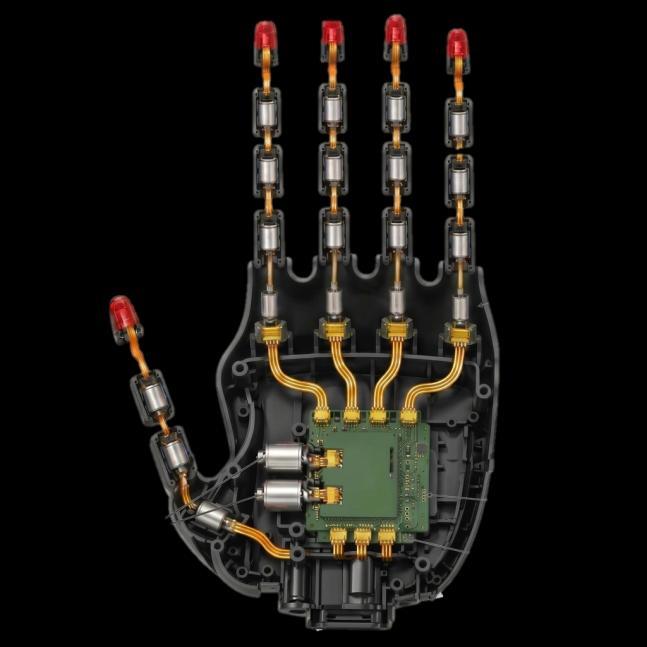
Enables precise manipulation, gripping, and interaction with objects
• Finger Actuators
• Force Sensors
• Hand Controller PCBs
Recommended Solutions
• High Speed I/Os
• Board to Board Connectors

• FPC Connectors
• Signal Wire to Board Connectors











Recommended Solutions
• Board to Board Connectors
• FPC Connectors

• Power & Signal Wire to Board Connectors
• Cables









• Board to Board Connectors
• Antenna Recommended Solutions



• High Speed I/Os
• Signal Wire to Board Connectors



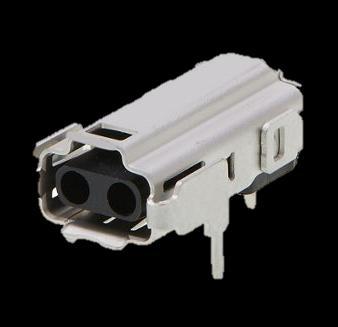
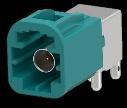
HFM cable 1m, Straight Jack to Jack OTS
Speed Fakra Mini (HFM), 2x2, Key Z





Recommended Solutions
• Power Connectors
• Board to Board Connectors
• FPC Connectors

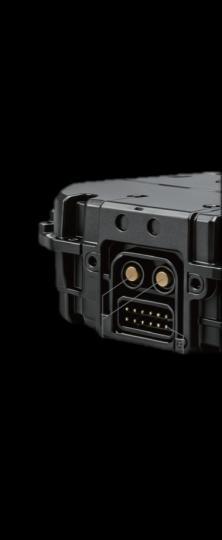
• Cables
• Power & Signal Wire to Board Connectors





Recommended Solutions
• Tactile Sensors
• High Speed I/Os

• Board to Board Connectors

• FPC Connectors
• Signal Wire to Board Connectors