
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
Tejal Kakade¹, Gauri Chaudhari¹, Saniya Mahadik¹, Sairaj Gunjal¹, Prof. Sonali Kathare²
¹Final-year students of Pillai College of Engineering, New Panvel, and the Department of Electronics and Telecommunication Engineering
²Assistant Professor, Department of Electronics and Telecommunication Engineering, Pillai College of Engineering, Navi Mumbai, Maharashtra, India
Abstract - Efficient and reliable medicine delivery within hospitals is a critical requirement for ensuring timely treatment and reducing the workload on healthcare staff. Manual distribution often results in delays and inefficiencies, especially in large healthcare facilities. This paperpresentsMediAstra,anautonomousmedicinedelivery robot designed to automate hospital logistics. The system integrates a Raspberry Pi 4 and Arduino Uno for coordinated control. IR sensors enable path following, ultrasonic sensors provide obstacle detection, and a camera moduleperformsQRcode-basedroomidentification.Aservo motor with keypad-based password access ensures secure medicine dispensing. The six-wheel chassis enhances mobilityover uneven indoor surfaces. Additionally, a mobile application provides real-time tracking and delivery notifications. The proposed system improves efficiency, reduces human workload, and enhances security in hospital medicinedistribution.
Key Words: Autonomous Robot, Medicine Delivery, Raspberry Pi, Arduino Uno, IR Sensors, QR Code Detection, Ultrasonic Sensors, Smart Healthcare
Effective medicine distribution is a crucial aspect of hospitals running efficiently and providing good patient services, but manual distribution by hospital staff can be pronetodelaysandextraworkload.Tosolvethisproblem, this project proposes the use of MediAstra, a self-guided medicine delivery robot that will be used to automate hospital logistics in a safe and trustworthy way. The project is based on a Raspberry Pi 4 controller that manages IR sensors for path tracking, a Pi Camera for QR code-based room detection, and ultrasonic sensors for real-time obstacle detection. A servo motor-controlled container with a 4×4 keypad provides safe access to medicines, while a six-wheel stair-climbing robot body provides smooth motion on irregular surfaces. Moreover, a mobile app provides real-time tracking and delivery statusupdates.
Hospitalsfacesignificantchallengesinensuringtimely, accurate,andsecuremedicinedeliverytopatients.Manual delivery by nurses or attendants often results in delays,
increased workload, and higher chances of distribution errors. In large healthcare facilities, staff must travel long distances, which disrupts critical patient care duties. Additionally, traditional systems lack real-time tracking and verification, creating accountability and security issues. Therefore, there is a need for an autonomous and reliable robotic solution to improve hospital logistics efficiency.
The objective of this project is to develop an autonomousmedicinedeliveryrobotcapableofefficiently transportingmedicineswithinhospitalenvironments.The systemintegratesIRsensorsforpathnavigation,acamera module for QR code-based room identification, and ultrasonic sensors for real-time obstacle detection. A servo-controlled container with keypad-based authentication ensures secure medicine access. A mobile application provides real-time tracking and delivery notifications to enhance reliability and operational efficiency.
The MediAstra system integrates hardware and software components to achieve autonomous navigation, secure medicine dispensing, and real-time monitoring. The overalldesignconsistsofRaspberryPi4andArduinoUno workingincoordinationtocontrolsensors,actuators,and communication modules. The system architecture is represented through the block diagram and circuit diagram, illustrating the interaction between navigation, detection,andcontrolunits.
The field of healthcare robotics and hospital automation has seen significant advancements in recent years, with researchers exploring robotic delivery systems, autonomous navigation methods, and IoT-based solutions to enhance hospital efficiency. Automated Guided Vehicles (AGVs) and mobile service robots have been introduced in hospitals to transport medicines, samples, and documents, reducing staff workload and improvinglogistics.
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
Line-following robots have been widely studied as a cost-effective navigation method, where Infrared (IR) sensors are used to detect black paths on the floor, providing simple yet reliable guidance [1]. To improve room identification, QR code-based navigation has emerged as a promising approach, enabling robots to localize themselves by reading QR markers placed along corridors or at doorways [2]. Ultrasonic sensing technologies have been integrated into mobile robots to achieve real-time obstacle detection, ensuring safer navigationincrowdedenvironmentssuchashospitals[3].
Mobile applications and IoT-based communication platforms have also been developed to facilitate interaction between hospital staff and delivery robots. These applications enable real-time notifications, live tracking, and status monitoring, ensuring transparency and reliability of the delivery process [4]. Furthermore, robotics research has also focused on stair-climbing mechanisms, inspired by planetary rovers, which allow robots to traverse irregular hospital terrains, ramps, and smallstaircases[5].
While these advancements demonstrate substantial progress in healthcare automation, challenges remain in integrating multiple technologies into a single, costeffective, and scalable solution. Future research is expected to focus on improving robot adaptability, enhancing security in medicine delivery, and developing intelligent cloud-based management systems to achieve greaterefficiencyandaccessibilityinhospitallogistics.
2.2
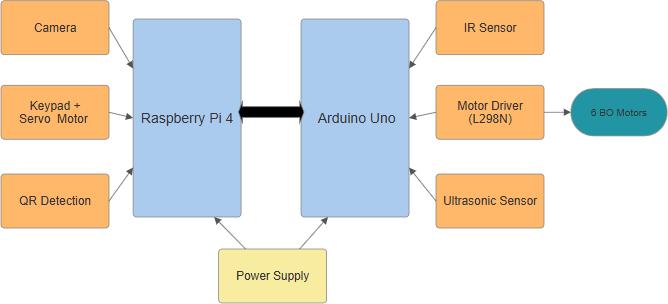
This is the block diagram of the MediAstra system, which represents the overall working and functional architecture of the project. It illustrates the interaction between the major hardware components and control units used in the system. The design integrates the Raspberry Pi 4 and Arduino Uno for coordinated and efficientcontrolofvariousoperations.
The Arduino is responsible for handling low-level control tasks, including interfacing with sensors such as
the IR sensor for line following and the ultrasonic sensor for obstacle detection. It also controls the L298N motor driver,whichregulatesthemovementanddirectionofthe six BO motors used for navigation. Meanwhile, the RaspberryPiperformshigh-levelprocessingtaskssuchas camera-based QR code detection, keypad input verification, and servo motor operation for secure medicine dispensing. The power supply unit provides the required and stable voltage to both controllers and all connected modules, ensuring smooth and uninterrupted systemoperation.
2.4 Components
The MediAstra system consists of various hardware components that work together to achieve autonomous navigation, obstacle detection, secure medicine dispensing, and real-time monitoring. The major componentsusedinthesystemaredescribedbelow.
2.4.1 Raspberry Pi 4B
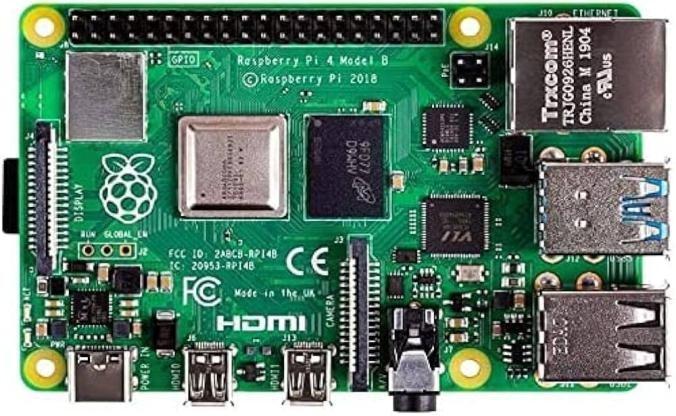
The Raspberry Pi 4 Model B is a powerful single-board computer with a 1.5 GHz quad-core ARM Cortex-A72 processor, up to 8 GB RAM, and built-in Wi-Fi, Bluetooth 5.0,andGigabitEthernet.Itsupportsdual4Kdisplaysand offers USB 3.0 connectivity along with a 40-pin GPIO for
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
sensor and device interfacing. Its high performance and versatility make it ideal for IoT, robotics, and automation projects. In the MediAstra system, it performs high-level processing tasks such as QR code detection, keypad authentication,andservomotorcontrol.
2.4.2
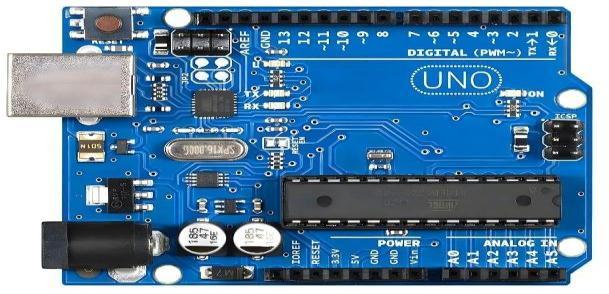
TheArduinoUnoisanopen-sourcemicrocontrollerboard based on the ATmega328P. It operates at 5V with a 16 MHz clock frequency and provides 14 digital input/output pins (6 PWM), 6 analog input pins, and a USB interface for programming and communication. It is widely used for prototyping and embedded applications due to its simplicity, affordability, and extensive library support. In this project, the Arduino Uno controls the motors, IR sensors, ultrasonic sensor, and Bluetooth module to manage the robot’s movement and obstacle detection.
2.4.4
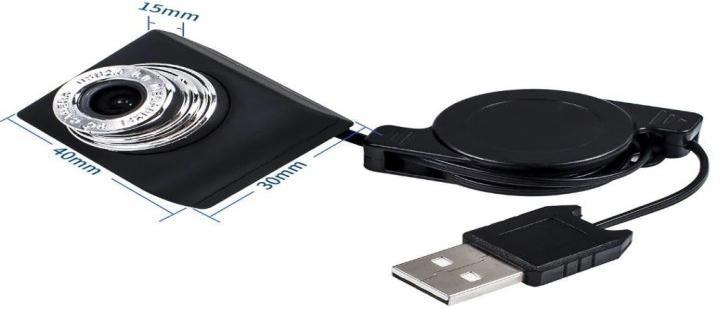
The CMOS Raspberry Pi Camera is used for QR code detectionandroomidentificationintheMediAstra robot. Itcaptureshigh-qualityimagesandtransmitsthemtothe Raspberry Pi for processing. The camera connects to the Raspberry Pi via the CSI (Camera Serial Interface) port, ensuring fast image transfer. It features a compact CMOS sensor that provides sharp images with low power consumption, enabling accurate recognition and efficient navigationduringmedicinedelivery.
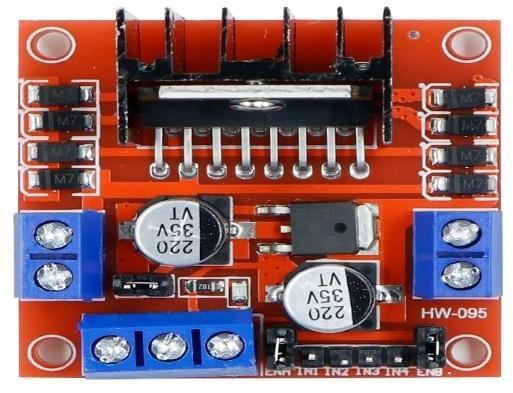
TheL298NMotorDrivercontrolsthedirectionandspeed oftheDCBOmotorsintheMediAstra robot.ItusesanHbridge configuration to drive two motors for forward, backward, left, and right movement. The key pin connectionsareENA(10),ENB(5)forspeedcontrol,IN1–IN4(9,8,7,6)fordirection, +12V for motor power, 5V OUT to Arduino, and GND as thecommonground.Itensuresefficientandstablemotor operation.
2.4.5
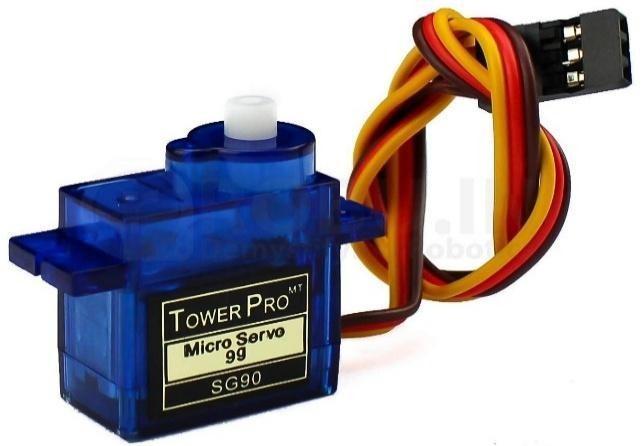
The Servo Motor in the Medi Astra robot is used to open and close the medicine container lid securely during delivery. It operates based on precise angular control, allowing the lid to rotate to a specific position when an authorizedpasswordisentered.Theservohasthreepins: VCC connected to 5V, GND to ground, and Signal to a Raspberry Pi GPIO pin for control. This mechanism ensures accurate, reliable, and automated medicine dispensing.
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
stop or change direction to avoid collisions. This configuration ensures stable and precise control over motion , making it suitable for reliable indoor navigation withinhospitalenvironments.
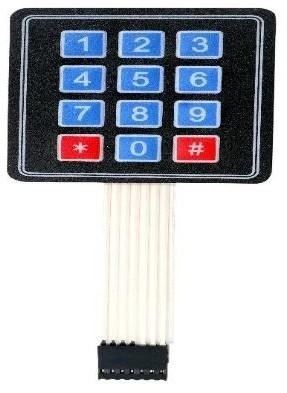
The3x4KeypadisusedintheMediAstrarobottoprovide a secure password-based access system for medicine retrieval.Itconsistsof12keysarrangedin3columnsand 4 rows, allowing users to enter numeric codes. The keypad connects to Raspberry Pi through GPIO pins, which detect key presses using a row-column scanning method.Itsconnectionsinclude7 pins(4row pinsand 3 columnpins)linkedtodigital GPIOs,VCC to5V,andGND to ground. This ensures safe and authorized medicine deliverycontrol.
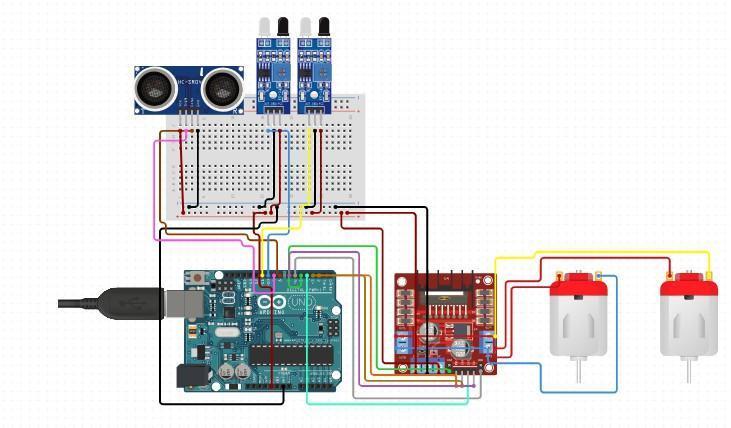
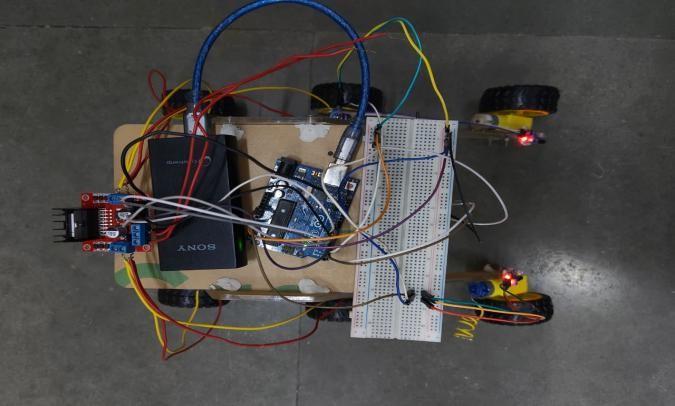
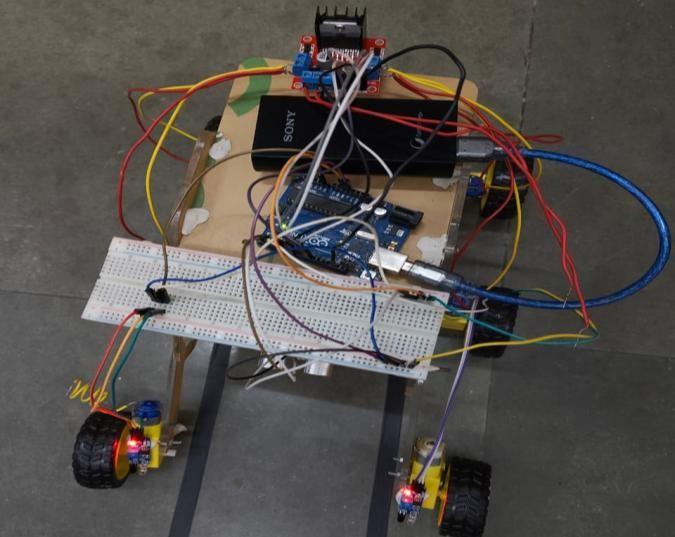
The Fig.3.1 illustrates the Arduino Uno interfaced with theL298Nmotordriver,IRsensors,andultrasonicsensor toformtheprimarymotioncontrolandnavigationunitof theMediAstrarobot.TheArduinosendscontrolsignalsto the L298N motor driver, which drives the DC motors responsiblefortherobot’smovement.TheIRsensorsare connected to detect the black line on the floor for path following, enabling the robot to navigate predefined routes autonomously. The ultrasonic sensor is used for real-time obstacle detection by measuring the distance betweentherobotandsurroundingobjects,allowingitto
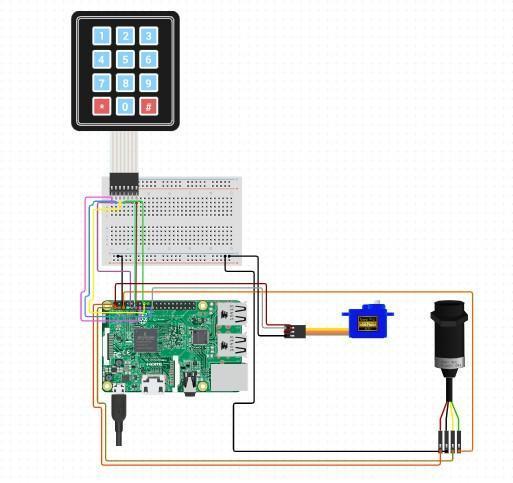
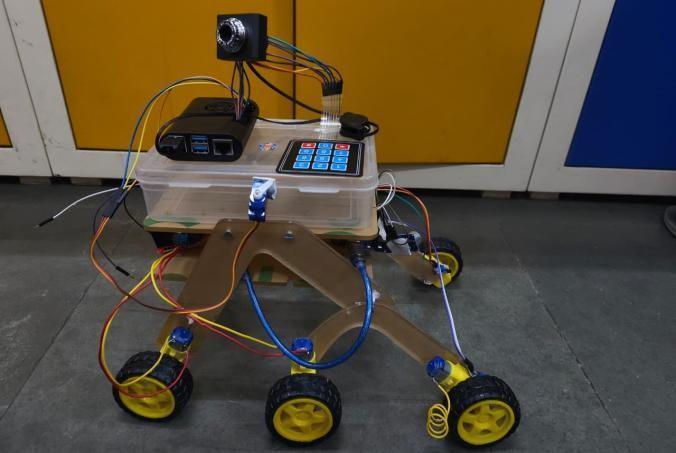
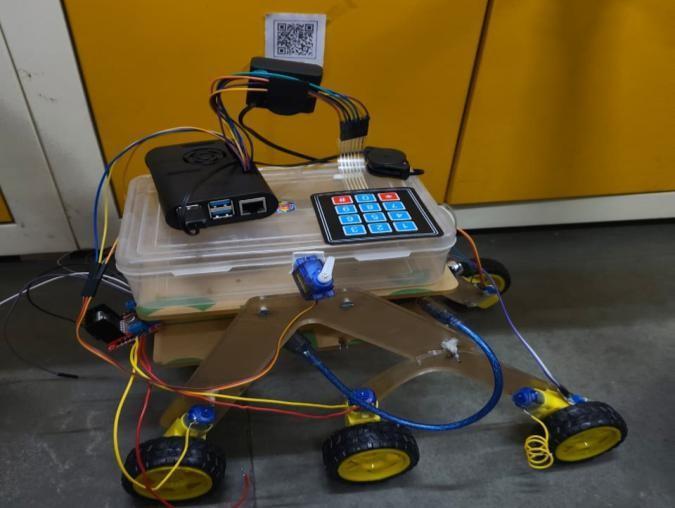
TheFig.3.2illustratestheRaspberryPi4interfacedwith a camera module, 3×4 keypad, and servo motor, forming theintelligentcontrolsectionoftheMediAstra robot.The RaspberryPi 4processesimagescaptured bythecamera todetectanddecodeQRcodesplacedatdifferenthospital rooms, ensuring accurate identification of the medicine delivery location. The 3×4 keypad is used as a security input system, allowing authorized personnel to enter a password to access the medicine container. Once the correct password is entered, the servo motor is actuated to open the lid, enabling secure medicine retrieval. After the process, the servo returns to its initial position to close the lid automatically. This setup enhances both security and automation in hospital logistics by ensuring that only authenticated users can access the delivered medicines.
TheFig3.3illustratestheworkingoftheIRsensor-based line-following mechanism used for autonomous navigation in the MediAstra robot. The IR sensors continuously detect the contrast between the black line
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
andthewhitefloorsurface.Whenthesensorpassesover the black line, it produces a low output signal, while on thewhitesurface,itgivesahighoutput.Thesesignalsare processed by the Arduino to adjust the motor speed and direction, ensuring the robot follows the path accurately. This system allows the robot to move smoothly along a predefined route within the hospital premises, ensuring reliable and efficient medicine delivery without the need formanualguidance.
The Fig 3.4 illustrates the camera-based QR code detection mechanism used in the MediAstra robot for accurate room identification and medicine delivery verification.Thecamera,interfacedwiththeRaspberryPi 4, continuously scans the surroundings as the robot follows its path. When it reaches a room, the camera capturestheQRcodeplacednearthedoorandprocesses theimagetodecodetheinformation.Thedecodeddatais compared with the preassigned delivery location stored in the system. If the QR code matches the designated room, the robot confirms its position and initiates the medicine delivery sequence. This ensures precise and error-freedeliverytothecorrectrecipient,enhancingthe reliability and automation of the hospital logistics process.
1)Automated Medicine Delivery in Hospitals
MediAstra automatestheprocessofdeliveringmedicines from the hospital pharmacy to patient rooms, reducing the manual workload on nurses and staff. It ensures timely and accurate medicine delivery, improving efficiencyandminimizinghumanerrors.
2)Enhanced Hospital Workflow Management
By following predefined paths and QR-based room identification, the robot optimizes hospital logistics. It allows staff to focus on patient care instead of routine deliverytasks,resultinginsmootherhospitaloperations.
3)Contactless Delivery for Infection Control
In sensitive hospital environments, MediAstra enables contactless medicine delivery, minimizing the risk of infection spread between patients and staff, especially duringpandemicorquarantinesituations.
4)Secure and Authorized Medicine Access
Akeypadandservo-controlledlidmechanismensurethat only authorized personnel or patients can access the delivered medicines, maintaining safety and accountabilityinhospitaloperations.
5)Scalable Use in Smart Healthcare Systems
MediAstra’s modular design and IoT-based connectivity make it adaptable for larger hospital networks. It can be expanded to transport samples, documents, or equipment, supporting future smart healthcare automation.
The MediAstra system presents an innovative and practical approach to automating medicine delivery within hospital environments. By integrating Raspberry Pi and Arduino platforms, the system effectively
International Research Journal of Engineering and Technology (IRJET) e-ISSN: 2395-0056
Volume: 13 Issue: 03 | Mar 2026 www.irjet.net p-ISSN: 2395-0072
coordinatestaskssuchaslinefollowingusingIR sensors, obstacle detection through ultrasonic sensors, QR-based room identification via a camera, and secure medicine dispensing with a servo–keypad mechanism. This combination of hardware and intelligent control not only reduces manual workload but also ensures timely and accurate medicine delivery to patients. The prototype demonstrates how robotics and IoT can transform healthcarelogisticsbyincreasingefficiency,accuracy,and safety. Future improvements could include cloud integration for real-time hospital database connectivity, enhanced path mapping, and multi-robot coordination to createafullyautonomoushospitaldeliverynetwork.
[
1] A. K. Mishra and P. S. Dhekne, “Design and Implementation of Line Following Robot Using Infrared Sensors,”InternationalJournalofScientificResearchand Engineering Development (IJSRED), vol. 3, no. 4, pp. 205–210,2020.
[2] S. K. Singh, R. Sharma, and M. Gupta, “Autonomous Navigation of Service Robot Using QR Code and Sensor Fusion,”IEEEAccess,vol.8,pp.145236–145245,2020.
[3] J. Wang, L. Zhang, and H. Chen, “Obstacle Avoidance for Mobile Robots Based on Ultrasonic Sensors,” International Journal of Advanced Robotic Systems, vol. 17,no.2,pp.1–10,2021.
[4] R. Bhosale and N. Patil, “IoT-Based Real-Time Monitoring and Control for Hospital Delivery Robots,” International Journal of Engineering Research & Technology(IJERT),vol.10,no.6,pp.450–455,2021.
[5]S.Park,H.Kim,andT.Lee,“DesignandDevelopment of a Stair- Climbing Mobile Robot for Logistics and DeliveryApplications.