Inpastfewyears,Robotsareusedformanycleaning works. Itisdesignedtoconsumelesstimeand reduce manworks, It has different kind of washing uses such as,mopping, picking the waste up,to remove the strain dirt ,litterandobstruction,topreventinjuriesduetotrippingandslipping.Itmayhavemanyadvantagesanddisadvantages.It ismadeforhomeandofficeenvironments,thisrobotuseswaterstoragewithantiinfection.Aftergettingcommandsfrom the android application cleans the area using cleaning pad through spraying water on the floor , it cleans the floor after thatitdrainsthewaterinthecontainer.Theactionofthetherobotcontrolledbytheandroidapplicationsthatisdescribed bytheuseranditworksmanually. Thesedays,Allofusleadsalifewherewedon’thavemuchtime.Personsincitieshaveatypicalandlengthyworkinghours. Inthosesituationpeoplealwaysfindwaysofsavingtime.generally incleaningfloorswiththeuseofdryorwetmopped byhandasabasetool,theyneedtobebrushedhardonthesurfaces whichhaveirregularareaslikecementedfloorsare filledwithheavyduststakesmuchtimetoclean,itishardtohandleforthosewomeswhoarecareer orientedtotakecare ofhomeandworkplaceatthesametime.
International Research Journal of Engineering and Technology (IRJET) e ISSN: 2395 0056 Volume: 09 Issue: 01 | Jan 2022 www.irjet.net p ISSN: 2395 0072 © 2022, IRJET | Impact Factor value: 7.529 | ISO 9001:2008 Certified Journal | Page706 SMART FLOOR CLEANING ROBOT USING ANDROID Mrs .Shritika Wayker(Asst.Proffesor)1 , Prashant Tiwari2 , Vishal Kumar3 , Kunal Limbu4 , Amay Tawade5 1 5Deparatment of Electronics and Telecommunication, Dr D.Y. Patil Institute of Engineering Management and Research Akurdi, Pune, Maharashtra, India. *** ABSTRACT
Ultrasonic
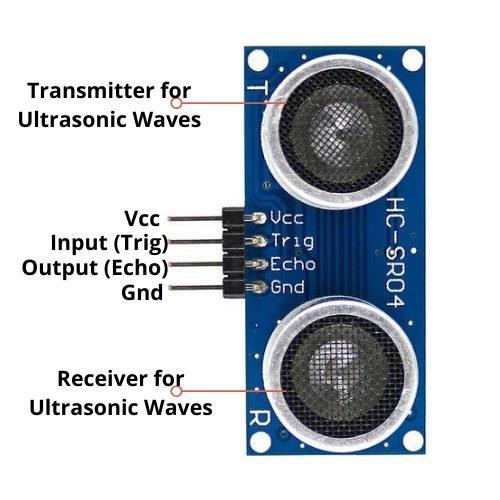
COMPONENTS UNO Sensor UltrasonicSensoris usedasadistancedetector,whenanultrasonicsensordetectsabarrierinfront ofit,therobotwillautomaticallysearch foradirectionthatisnotahurdletothefloorcleaningrobot.
KEYWORDS AurduinoUNO,BluetoothModule,IRSensorsandMotordrivers.
INTRODUCTION
ThedevelopmentcontrivedintechnologyofroboticshavemadelifeofHumankind excessivelyeffortlessand congenial.ThispaperpresentsaCosteffectiverobotthatcanbeusedbypeoplewhocan’tbeabletoenjoycomfort.Thereis heterogeneity of autonomous robots provided in the market and they all performs excellently according to their requirements but none of them are costeffective..this system comprised of a transmitter application that works on an android mobile app which permit the robot to follow the instruction given by the user through the transmitter app. this system made up of Microcontroller(Ardunio UNO) that has fourteen input/output pins and cleaning ,robotic arm. The microcontroller,on getting the instructions from android device from Bluetooth receiver decodes the given instructions andcommandsthemotorstoacquirethedesiredpathanddirection.
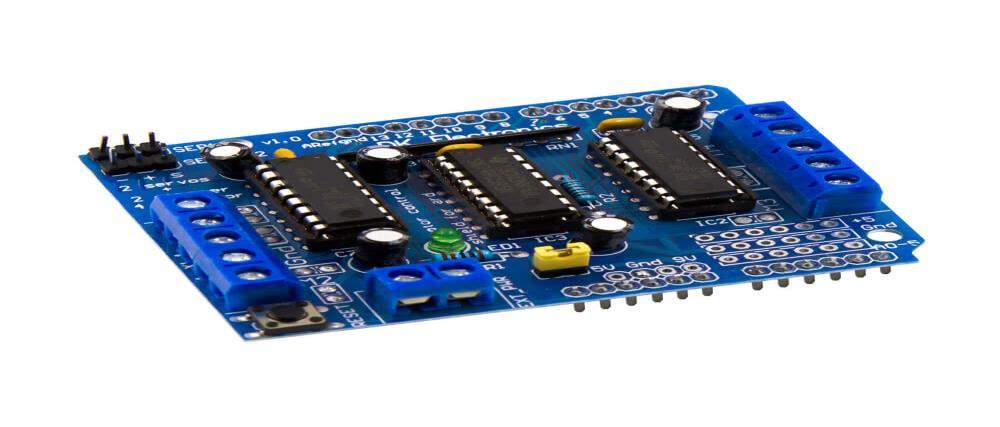
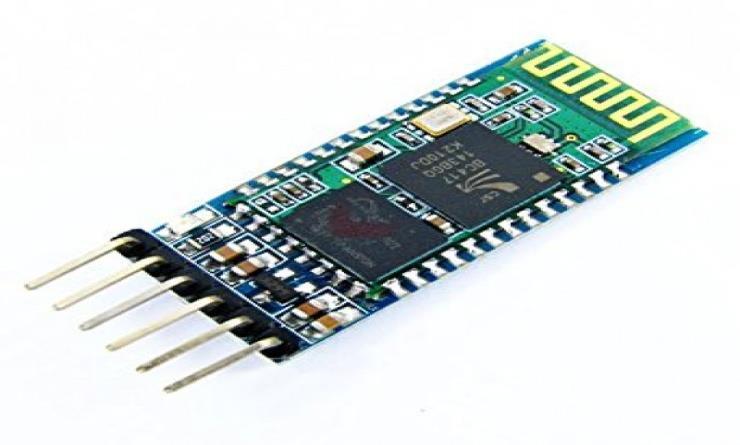
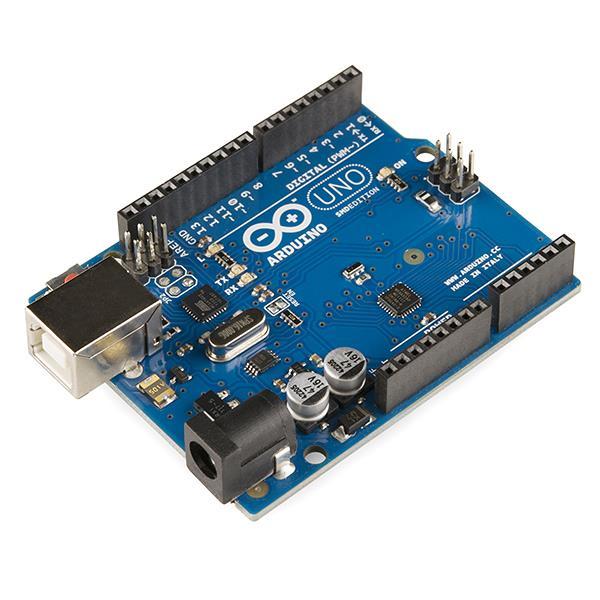
UltrasonicSensor Buzzer Motor L293D BluetoothModule Arduino

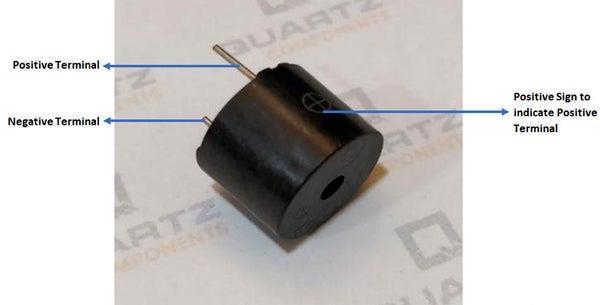
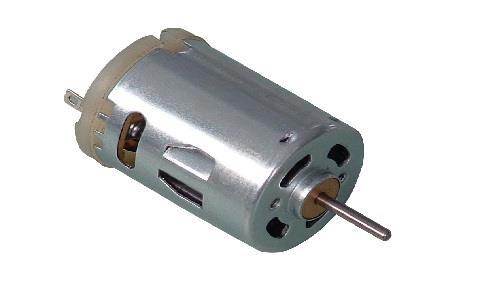
International Research Journal of Engineering and Technology (IRJET) e ISSN: 2395 0056 Volume: 09 Issue: 01 | Jan 2022 www.irjet.net p ISSN: 2395 0072 © 2022, IRJET | Impact Factor value: 7.529 | ISO 9001:2008 Certified Journal | Page707 Buzzer Buzzersgives indicationsofanobstacles. Motor DC Motorsareusedasrobotdrivers. L293D L293D isa16pinmotordriverIC, L293DisadualchannelH BridgemotordriverIC,usedtocontroletomotors.
International Research Journal of Engineering and Technology (IRJET) e ISSN: 2395 0056 Volume: 09 Issue: 01 | Jan 2022 www.irjet.net p ISSN: 2395 0072 © 2022, IRJET | Impact Factor value: 7.529 | ISO 9001:2008 Certified Journal | Page708 Bluetooth Module Bluetoothmoduleisusedtocontroletherobotusingandroidapplicationwithinitsrange. Arduino - ThisarduinoUNO microcontrollerprocessestheultrasonicsensorasadistancedetectorandaDCmotorasa robotdriver. LITRATURE SURVEY Nowdays,Smart floorcleanerrobotsaretrendingconcept.Afterseendifferent researchpapersandproceduresofusing many cleaning robots, a smart floor cleaning robot is an independent robotic cleaner which runs through mobile application.Thisrobotconsistofbrusher,watercontainer,cameraetc.Ithadfewdisadvantageslikehittingwithobstacles andstoppedatashorterspacefromwallsandotherobjects,toavoidobstaclesitusesultrasonicsensors.
Objectiveofthisprojecttodesigntheautomaticfloorcleaningrobottodevelopanautonomous roboticsystem. designafloorcleaningrobot withouthumentothedriving. achieve simultaneousdryandwetcleaninginasinglerun. makethemachinecosteffective. reducethemaintenancecostofmanuallyoperatedfloorecleaningasfaraspossible. BlockDiagram
To
To
:
VinodThomas,madeacleaningrobotforhouseholdsapplications.Itismade inorderthatmaycapable ofcleaningeveryspaceandeverycorneroftheroom.Rupinderkaur,madeaautomaticrobotwhichisabsolutelyfinefor cleaningpurposesmostlyinhomes,industries,malls,thisrobotcansweep andmop thehiddenarea.
Software Implementation
Explanation
TheaimofthisProjectistomakeafullyautomatedhomecleaningrobot,which isfullyautomaticand tiodotaskslike mopping,brushing,cleaningfloors, Aftercheckingwefindthatitcandoalltaskswellwithnoanyhurdle,we havetested itinmanyparameterslikeobstacleavoiding,mopping,navigation andvaccummechanism.
To
This project deals with the designing and fabrication of floor Cleaning robot. The aimof project work is to develop and modernized processforcleaning. Themainobjectiveof thisproject isto achievesimultaneouslydryandwet cleaning In single run. It is used in houses, hospitals, shops, schools, collages, malls, etc. Cleaning of floor is very important for our health and reduces the major power necessity. This project work in manually andautomatic. all hardware and software operations are controlled by Arduino. It consist of moisture cotton brush, the brush cleans the floor and dried with the helpofblower.
OBJECTIVES
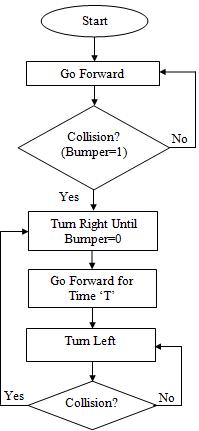
Theorderofimplementingpreferdmodelisshownbelowintheformofflowchart.
International Research Journal of Engineering and Technology (IRJET) e ISSN: 2395 0056 Volume: 09 Issue: 01 | Jan 2022 www.irjet.net p ISSN: 2395 0072 © 2022, IRJET | Impact Factor value: 7.529 | ISO 9001:2008 Certified Journal | Page709
To
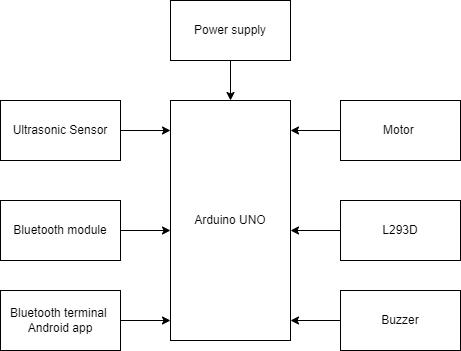
International Research Journal of Engineering and Technology (IRJET) e ISSN: 2395 0056 Volume: 09 Issue: 01 | Jan 2022 www.irjet.net p ISSN: 2395 0072 © 2022, IRJET | Impact Factor value: 7.529 | ISO 9001:2008 Certified Journal | Page710 :FlowChart
RESULT a hard ware model has been made with the plan of making floor cleaning easy, quickly and congenial android mobileapplicationsforgivingcommands. CONCLUSION This research paper introduces that floor cleaning Process can be done in an easy manner and much expeditiouslybyrobottakingadvantageofwirelessroboticsystem.Thispreferredrobotsavesthetimeandcostoflabour Intheearlierresearchpapers,robothadfewdrawbackslikehitting otherobstaclesinfrontofitandthisbrushcleaners couldn’treachtosmallareasandleftthoseareaunclean.Thistwoproblemshavebeensolvedinthisrobot.
REFERENCES[1] Youngkak Ma,seungwoo Kim,Dongik Oh and Youngwan Cho, "Astudyon the development of home mess cleanup robotMcBot",IEEE/ASMEinternationalconferenceonadvancedmechatronics,July2 5,2008,Xian,China.
[2] Veerajagadheswar Prabakaran, Mohan Rajesh Elara, Thejus Pathmakumar and Shunsuke Nansai "hTetro: A Tetris inspired shape shifting floor cleaningrobot",IEEEInternational ConferenceonRobotics andAutomation(ICRA),May29 toJune3,2017,Singapore [3]S.Amit,AGaurandA.Rajpurohit,“FullyAutomatedhomecleaning”.InternationalJournalofEngineeringTechnologies andManagementResearch2018.